UAV Search & Rescue
A search-and-rescue drone that spots people from the air on its own, deciding on-board in real time instead of streaming to a server.
The problem
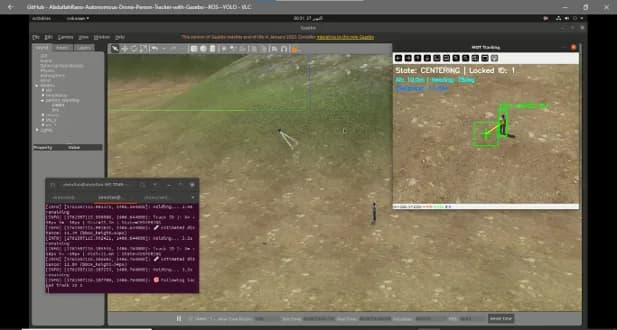
Search-and-rescue from a drone needs detection that runs on the aircraft in real time. Streaming video to a server and waiting is not an option when the compute and the link are both constrained.
What I built
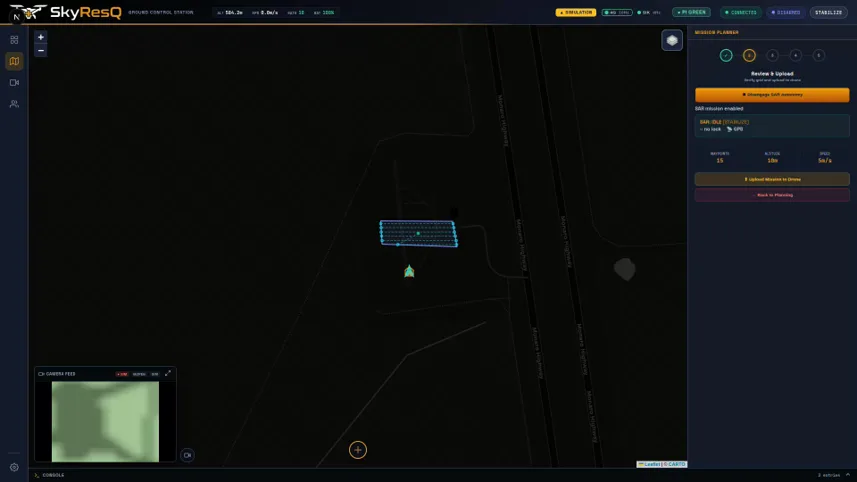
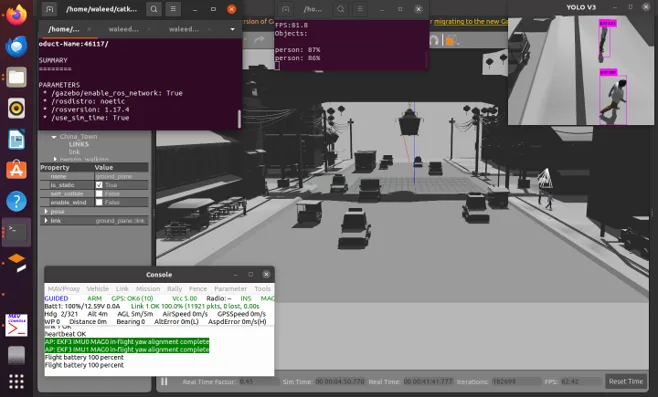
I built the autonomy and vision stack: YOLOv8 detection exported to ONNX and run on edge GPUs, wired into a ROS 2 system for autonomous flight, with detections distributed across compute so the aircraft decides on-board.
The outcome
Real-time on-board detection and autonomous search behaviour, with the heavy compute handled at the edge instead of a round-trip to a base station.
Inside it
Stack
- ROS 2
- YOLOv8
- ONNX
- PyTorch
- Edge GPU
Working on something like this?
Tell me what you are trying to build. I will tell you honestly whether it is worth doing.